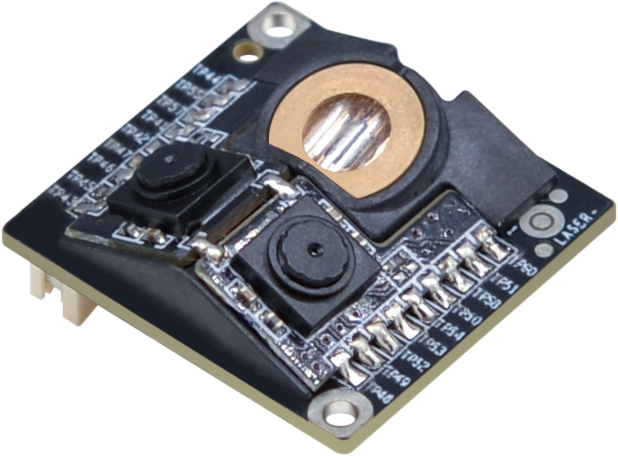
Common Myths About lidar sensor
The most persistent misconception is that lidar sensors are a solved problem—something that works flawlessly once installed. This assumption ignores the fundamental challenge of light-based measurement in dynamic environments. Unlike radar, which uses radio waves that penetrate fog and rain with relative ease, lidar’s reliance on visible or near-infrared light makes it highly sensitive to atmospheric interference. Snow, heavy rain, or even dense urban pollution can reduce effective range by 80% or more, yet many early adopters treated lidar as a plug-and-play solution. The result? High-profile failures in autonomous vehicle testing where sensors failed to detect pedestrians or obstacles due to weather conditions that weren’t accounted for in initial simulations. Another widespread myth is that lidar sensors outperform cameras and radar in every scenario. While lidar excels at creating high-resolution 3D point clouds—critical for tasks like autonomous navigation or archaeological site mapping—it’s not universally superior. Cameras, for example, can detect color and texture with far greater detail, while radar provides better long-range performance in harsh conditions. The reality is that lidar sensors are often complemented by other sensors in a multi-modal approach. Tesla’s early skepticism toward lidar (later reversed) stemmed from this exact point: relying solely on a single sensor modality risks catastrophic blind spots. Finally, there’s the belief that lidar sensors are prohibitively expensive, limiting their adoption to high-end applications. While early systems—like those used in the 2010s for autonomous prototypes—could cost upwards of $75,000 per unit, mass production has driven prices down to around $100–$500 for consumer-grade models. However, the cost isn’t just about the sensor itself but the entire ecosystem: data processing, calibration, and integration with other systems. A lidar-equipped autonomous vehicle may still require hundreds of thousands of dollars in additional hardware and software, making the technology accessible only to well-funded players—or those willing to accept lower performance.Myth 1: lidar sensor accuracy is absolute
The idea that lidar sensors provide flawless precision in all conditions is a dangerous oversimplification. Even under ideal circumstances, accuracy depends on multiple variables: the laser’s wavelength, the sensor’s field of view, and the reflectivity of the surfaces being scanned. A lidar system might achieve 1–2 cm resolution in a controlled lab, but real-world deployments—like a self-driving car navigating a construction site—often see errors creep into the 10–30 cm range due to sensor noise, misalignment, or temporary obstructions. The point cloud generated by a lidar sensor isn’t a perfect replica of reality; it’s a probabilistic model that requires sophisticated algorithms to interpret. Worse, accuracy degrades predictably with distance. Most automotive-grade lidar sensors lose meaningful resolution beyond 100–150 meters, even in clear conditions. This isn’t a limitation of the technology itself but a trade-off between power consumption, sensor size, and data throughput. Companies like Velodyne and Innoviz have made strides in extending range—some systems now claim 200+ meters—but these gains come at the expense of frame rate or vertical resolution. The lesson? Lidar sensors are precise tools, not magic wands. Their output is only as reliable as the context in which they’re used.Myth 2: lidar sensor is the only solution for autonomous vehicles
The narrative that lidar sensors are non-negotiable for autonomous driving has dominated headlines, but the data tells a different story. Waymo, often cited as the gold standard, initially relied heavily on lidar before shifting to a multi-sensor fusion approach that prioritizes radar and cameras for cost and robustness. Tesla’s decision to forgo lidar in early models wasn’t a technical failure but a strategic bet on computer vision and radar, which together can achieve 95% of the performance at a fraction of the cost. The key insight? Lidar sensors excel at high-precision localization but struggle with edge cases—like detecting a child on a bicycle at dusk—that cameras and radar handle better. This isn’t to dismiss lidar’s role. In regulated environments like mining or logistics warehouses, where obstacles are static and lighting is controlled, lidar sensors provide unmatched reliability. But in the chaotic, unpredictable world of urban driving, over-reliance on any single sensor modality is a risk. The most advanced autonomous systems today—like those from Zoox or Pony.ai—use dozens of sensors, blending lidar’s 3D mapping with radar’s long-range detection and cameras’ contextual awareness. The future isn’t about choosing one technology but orchestrating them.Myth 3: lidar sensor data is easy to process
The raw output of a lidar sensor—a flood of millions of data points per second—isn’t immediately useful. Converting this into actionable insights requires massive computational power, often measured in teraflops. A single lidar scan can generate 1–10 GB of data per hour, depending on resolution and frame rate. Processing this in real time demands specialized hardware, which is why autonomous vehicles need custom AI chips like NVIDIA’s DRIVE platform or Mobileye’s EyeQ series. The misconception that lidar data is "just points" ignores the algorithm-intensive work of filtering noise, stitching frames, and classifying objects—a process that can consume 90% of a vehicle’s onboard computing budget. Even with powerful hardware, the challenges persist. Occlusions—where one object blocks another—create gaps in the point cloud that algorithms must infer. Dynamic scenes, like pedestrians crossing streets, require temporal tracking to avoid false positives. Companies like Luminar and Ouster have made progress with deep learning-based point cloud processing, but these systems still demand constant retraining as environments evolve. The result? A feedback loop where better sensors require better algorithms, which in turn demand more powerful hardware—a cycle that keeps costs high and development timelines long.
What Holds Up to Scrutiny
At its core, the lidar sensor’s strength lies in its ability to reconstruct 3D space with unprecedented detail. Unlike cameras, which rely on perspective and require complex depth estimation, lidar measures distance directly via time-of-flight. This makes it ideal for applications where spatial accuracy is non-negotiable: autonomous navigation, archaeological surveys, or forestry inventory. In these domains, lidar sensors have become the gold standard, outperforming alternatives in controlled or semi-controlled environments. For example, lidar-equipped drones can map a 500-acre forest in hours, generating terrain models accurate to within centimeters—something photogrammetry alone couldn’t achieve. The technology’s evolution has also addressed some early limitations. Solid-state lidar, which replaces mechanical spinning mirrors with semiconductor-based emitters, has shrunk form factors while improving reliability. Companies like Hesai and RoboSense now offer systems that fit inside a shoebox yet deliver performance comparable to bulkier predecessors. Meanwhile, advances in multi-beam scanning—where a single sensor emits hundreds of laser pulses simultaneously—have reduced the time needed to build a complete 3D model. These improvements have made lidar sensors viable for consumer electronics, such as the iPad Pro’s depth-sensing capabilities or the upcoming lidar-equipped smartphones from Apple and others."Lidar isn’t about replacing other sensors—it’s about completing the picture. The best systems today use a mix of modalities, but lidar’s unique ability to see in the dark or through light fog makes it irreplaceable for safety-critical applications." — Dr. Ann Majewicz, Senior Researcher, MIT Autonomous Systems Lab
| Common Belief | What the Evidence Says |
|---|---|
| Lidar sensors work perfectly in all weather. | Performance drops sharply in rain, snow, or fog—some systems lose 50–80% range in heavy precipitation. |
| More lidar points = better accuracy. | Denser point clouds improve detail but increase computational load; optimal resolution depends on the use case. |
| Lidar is too expensive for mass adoption. | Unit costs have fallen to $100–$500, but total system integration (processing, calibration) remains a barrier. |
Why the Confusion Persists
Part of the problem is marketing hype—vendors and media often frame lidar sensors as a panacea, obscuring their limitations. Early adopters in autonomous vehicles, for instance, treated lidar as a silver bullet, only to encounter unforeseen challenges in real-world testing. The result was a backlash that painted lidar as overhyped, when in reality, the issue was poor integration rather than the technology itself. Similarly, the rapid pace of innovation means that what was cutting-edge two years ago—like 64-channel lidar—is now considered baseline, creating a perception of stagnation. Another factor is the lack of standardized benchmarks. Unlike cameras, which have well-defined metrics like resolution or dynamic range, lidar performance is measured in disparate ways: range, field of view, point density, and error rates. This fragmentation makes it difficult for buyers to compare systems fairly. Industry groups are working on solutions—such as the Automotive Grade Linux consortium’s sensor fusion standards—but progress is slow. Until then, confusion will persist, with some vendors overpromising and others underdelivering.
Conclusion
Lidar sensors have come a long way since their debut in space exploration, but their role in modern technology is still evolving. They’re not a one-size-fits-all solution, nor are they a magic bullet for autonomous systems. Instead, they’re a specialized tool that excels in niche applications where 3D precision is critical. The most successful deployments—whether in self-driving cars, drones, or industrial inspection—treat lidar as part of a broader sensor suite, compensating for its weaknesses with complementary technologies. The next frontier lies in miniaturization and cost reduction, particularly for consumer markets. As lidar sensors become smaller and cheaper, their integration into smartphones, AR glasses, and even home robots will accelerate. But the real breakthroughs will come from better algorithms that make sense of lidar data in real time, reducing the reliance on brute-force computing. Until then, the technology’s potential remains tantalizingly within reach—if only we stop treating it as a solved problem and start treating it as the complex, evolving system it is.Comprehensive FAQs
Q: How does a lidar sensor actually measure distance?
A: Lidar sensors work by emitting pulsed or continuous laser beams and measuring the time it takes for the light to reflect off an object and return. The distance is calculated using the speed of light (approximately 30 cm per nanosecond). Most automotive lidar systems use time-of-flight (ToF) or phase-shift methods, where the phase difference between emitted and received signals helps determine range. Higher-end systems may use frequency-modulated continuous-wave (FMCW) lidar, which offers better resolution at longer distances.
Q: Can lidar sensors work underwater?
A: Traditional lidar sensors fail underwater because water absorbs and scatters light, especially at the wavelengths used in air-based systems (typically 905 nm or 1550 nm). However, underwater lidar exists, using blue-green lasers (around 532 nm) that penetrate water better. These systems are used in marine archaeology, offshore inspection, and autonomous underwater vehicles (AUVs), but they require specialized optics and shorter ranges due to absorption over distance.
Q: Why do some autonomous cars use lidar while others don’t?
A: The choice depends on trade-offs between cost, performance, and environmental robustness. Companies like Waymo and Zoox prioritize lidar for its high-precision 3D mapping, especially in complex urban environments. Others, like Tesla, rely on radar and cameras for lower-cost, more weather-resistant solutions, accepting slightly lower accuracy in exchange for reliability. The trend now is toward hybrid systems, where lidar handles critical tasks (e.g., pedestrian detection) while other sensors manage long-range awareness.
Q: How accurate are lidar sensors in mapping?
A: Accuracy varies widely. High-end automotive lidar can achieve 1–5 cm precision at close range (under 50 meters), but this degrades with distance—expect 10–30 cm errors at 100+ meters. Aerial lidar (used in surveying or archaeology) can reach sub-centimeter accuracy over large areas, but this requires ground control points and post-processing. The key limitation isn’t the sensor itself but environmental noise, calibration drift, and data processing—factors that can introduce cumulative errors over time.
Q: Are lidar sensors safe for human eyes?
A: Most lidar sensors operate at Class 1 or Class 1M laser safety levels, meaning the emitted power is below the threshold for eye damage under normal use. However, direct exposure to high-power lidar beams (e.g., in industrial or military applications) can still pose risks. Consumer-grade lidar, like that in smartphones or AR devices, uses eye-safe wavelengths (typically 905 nm or 1550 nm) with power levels well below regulatory limits. That said, prolonged staring at a lidar emitter—even at safe levels—can cause discomfort due to bright laser reflections.
Q: What’s the difference between lidar and radar?
A: The primary difference lies in the type of waves used and their interaction with the environment. Lidar uses light (lasers), which provides high resolution but struggles with transparency (e.g., fog, rain). Radar uses radio waves, which penetrate adverse conditions better but offer lower spatial resolution. Lidar excels at short-to-medium range (1–200 meters) with centimeter-level precision, while radar dominates long-range detection (200+ meters) in poor visibility. Many autonomous systems combine both for complementary strengths.
Q: Can lidar sensors detect color?
A: No, traditional lidar sensors measure distance and intensity (reflectivity) but not color. However, some advanced systems—like color lidar—integrate RGB cameras to overlay color information onto the 3D point cloud. This is used in applications like autonomous driving (to distinguish a red stop sign from a red car) or cultural heritage documentation (to preserve color-accurate 3D models of artifacts). The trade-off is increased complexity and cost, as the system must synchronize laser scans with camera frames.
Q: How long do lidar sensors last?
A: Lifespan depends on usage and environmental conditions. Most automotive lidar sensors are designed for 100,000–200,000 miles of operation, with degradation occurring in the laser diodes or optical components over time. Industrial lidar (e.g., in warehouses or mining) may last longer—5–10 years—if protected from dust and extreme temperatures. Consumer lidar (e.g., in smartphones) typically degrades faster due to less robust sealing, with performance drops noticeable after 2–3 years of heavy use.
Q: Are there any lidar sensors that don’t use lasers?
A: Most lidar systems rely on lasers, but alternative approaches exist. Flash lidar uses a pulsed laser to illuminate an entire scene at once, reducing moving parts but increasing power consumption. Frequency-modulated continuous-wave (FMCW) lidar uses modulated light waves to measure distance via phase shifts, offering better range resolution. Some experimental systems explore non-laser light sources, like LED-based lidar, which uses structured light patterns (e.g., projected grids) to infer depth, though these lack the precision of laser-based methods.
